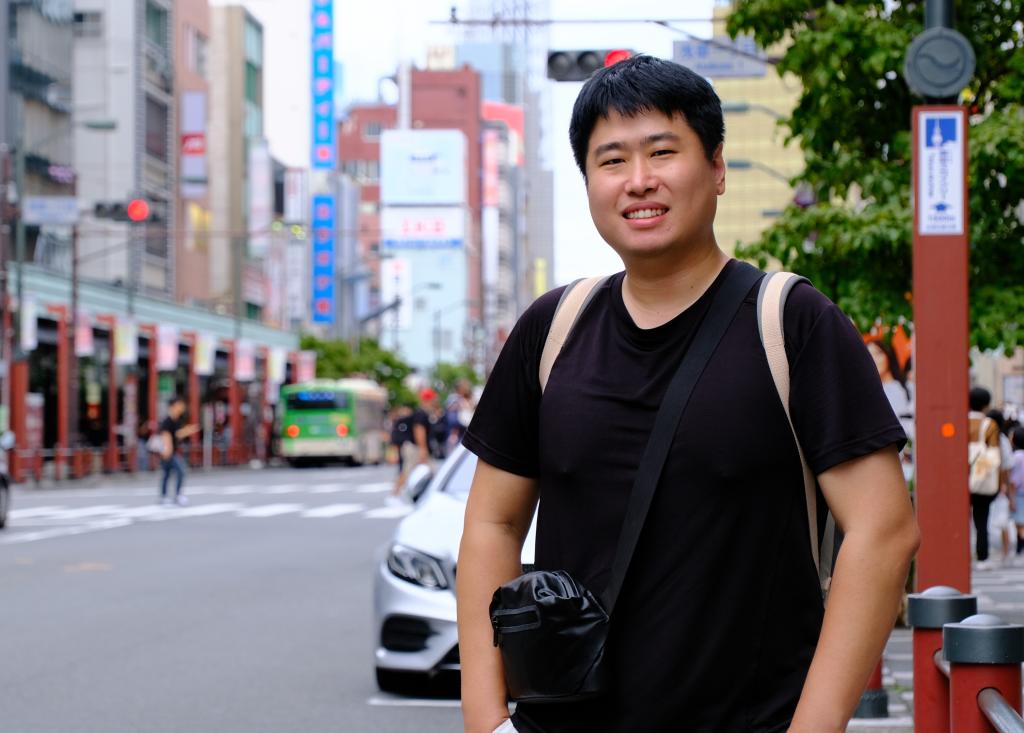
高煜欣,男,讲师,硕士生导师。2024年毕业于南京航空航天大学自动化学院,工学博士,现任天津中德应用技术大学航空航天学院讲师,兼任《Neural Computing and Applications》《Journal of Aerospace Engineering》《International Journal of Robust and Nonlinear Control》等期刊审稿人。
招生方向:
085500机械—03机器人技术
主要研究方向:多智能体协同控制、飞行器控制、智能控制算法。
主要科研项目及角色:
1. 国家自然科学基金青年项目“多源异质扰动耦合下电力巡检无人机编队鲁棒控制研究”(52602682),2027.01-2029.12,30万元,主持;
2. 天津市教育委员会科研计划项目“面向电力巡检的多无人机鲁棒协同控制技术”(2025KJ182),2025.12-2027.12,6万元,主持;
3. 中国高校产学研创新基金项目“复杂环境下无人机集群智能鲁棒协同控制”(2024ZY025),10万元,2025.08-2027.07,参与;
4. 国防XX项目“飞行器XXX研究”,2021.12-2024.12,100万元,参与;
5. 国家自然科学基金重点项目“无尾飞翼布局飞行器的操纵面故障强化学习最优自适应补偿控制研究”,(61473147),200万元,参与。
代表性论著及研究成果:
1. Yuxin Gao, Chunsheng Liu, Dandan Duan, and Shaojie Zhang. Distributed optimal event-triggered cooperative control for nonlinear multi missile guidance systems with partially unknown dynamics. International Journal of Robust and Nonlinear Control, 2022, 32(15): 8369-8396.
2. Yuxin Gao, Chunsheng Liu, Sen Jiang, and Shaojie Zhang. Distributed fuzzy learning sliding mode cooperative control for non-affine nonlinear multi-missile guidance systems via a prescribed performance observer. Journal of the Franklin Institute, 2023, 360(11): 7325-7356.
3. Yuxin Gao, Chunsheng Liu, Sen Jiang, and Shaojie Zhang. Zero-sum differential games-based fast adaptive robust optimal sliding mode control design for uncertain missile autopilot with constrained input. International Journal of Control, 2021, 3: 1-26.
4. 高煜欣, 刘春生. 基于微分对策的非仿射导弹学习滑模制导. 系统工程与电子技术, 2023, 4(15): 3616-3623.
5. 高煜欣, 张绍杰, 刘春生. 网络攻击下导弹自适应事件触发制导律研究. 航空学报, 2024,45(S1):464-473.
6. 杨俊起, 高煜欣, 陈滟涛, 崔立志. 基于干扰观测器的不确定非线性系统终端滑模控制器设计. 控制与决策, 2020, 35(01): 155-160.
7. Yuxin Gao, and Chunsheng Liu. Distributed optimal cooperative control for nonlinear multi-agent systems with input saturation and full-state constraint. Beijing, China: Proceedings of the 2021 China Automation Congress (CAC), 2021: 902-907.
8. 高煜欣, 刘春生. 一种基于全状态动态约束的分布式周期事件触发饱和协同制导方法. 授权公告号: CN114993108B(专利).
9. 高煜欣, 刘春生. 一种分布式最优事件触发协同制导方法. 授权公告号: CN114995129B(专利).
E-mail:gaoyuxin917@163.com


